医疗城 · 设备实验室 · 第 1 台,共 69 台
手术机器人
Surgical Robot
BMEssentia 医疗城设备实验室中的手术机器人。以可交互 3D 打开设备,逐个部件拆解,了解其工作原理,然后在 BMEssentia 平台上系统学习,并向 Essentia 提问。
本页的设备实验室内容为英文,与医疗城中的内容一致。
- 10 个部件
- 设备实验室中有 3 种配置
- 又称: Robotic Surgery System, Da Vinci
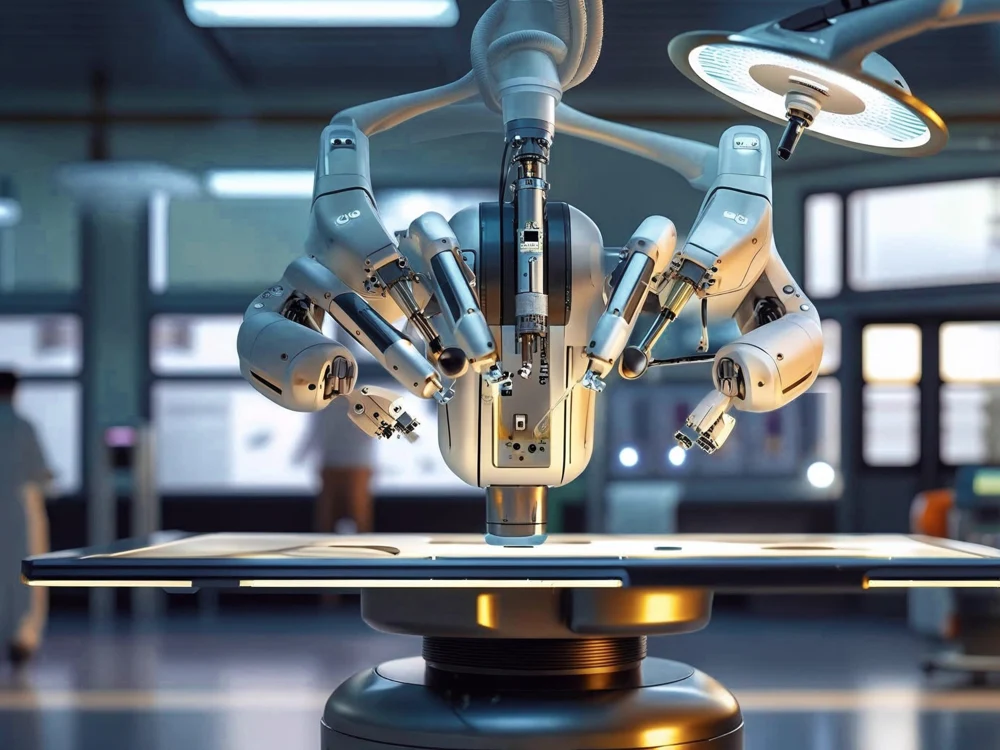
设备实验室
Surgical Robot
The console is an operator workstation, not an autonomous decision maker. Find the viewing interface, hand controls and foot controls as separate inputs and outputs.
部件
逐个部件讲解。
Surgeon console
The console is an operator workstation, not an autonomous decision maker. Find the viewing interface, hand controls and foot controls as separate inputs and outputs.
Viewing interface
A viewing interface turns the imaging chain into information the operator can use. The enclosed viewer and the open-console display are visibly different arrangements in this lab.
Master hand controls
The hand controls represent an input to the robot controller. The important relationship is between operator movement, the selected control mapping and instrument response.
Foot controls
Several functions may be assigned to foot controls in a real surgical system. Their shape and location are not enough to identify those functions across products.
System tower
The tower makes the distributed system visible. Its enclosure contains representative processing and power roles and supports a team display.
Team display and status interface
The bedside team needs a shared view of system status. The display in this lab reports the teaching state, input command and illustrative response.
Controller and processing electronics
The controller receives inputs and coordinates the represented drive response. It sits between a command and an actuator; it is not a guarantee that the physical system followed the command.
Power conversion and distribution
Power is a path through the system, not a single reassuring lamp. This schematic assembly represents the role of supplying usable electrical energy to processing and actuation.
System connections and communication
Follow the visible cables between console, tower and patient-side equipment. They make the distributed control problem tangible.
Patient-side base and supports
The base carries the mechanical assembly and transfers its loads to the floor. Compare a shared base with four independent carts.