المدينة الطبية · مختبر الأجهزة · الجهاز 1 من 69
الروبوت الجراحي
Surgical Robot
الروبوت الجراحي في مختبر الأجهزة في المدينة الطبية من BMEssentia. افتحه بتقنية ثلاثية الأبعاد تفاعلية، وفكّكه قطعةً قطعة، وتعرّف إلى طريقة عمله، ثم تعلّمه على منصة BMEssentia واسأل إسنشيا عنه.
محتوى مختبر الأجهزة في هذه الصفحة باللغة الإنجليزية، كما هو داخل المدينة الطبية.
- عدد الأجزاء: 10
- عدد التكوينات في مختبر الأجهزة: 3
- يُعرف أيضًا باسم: Robotic Surgery System, Da Vinci
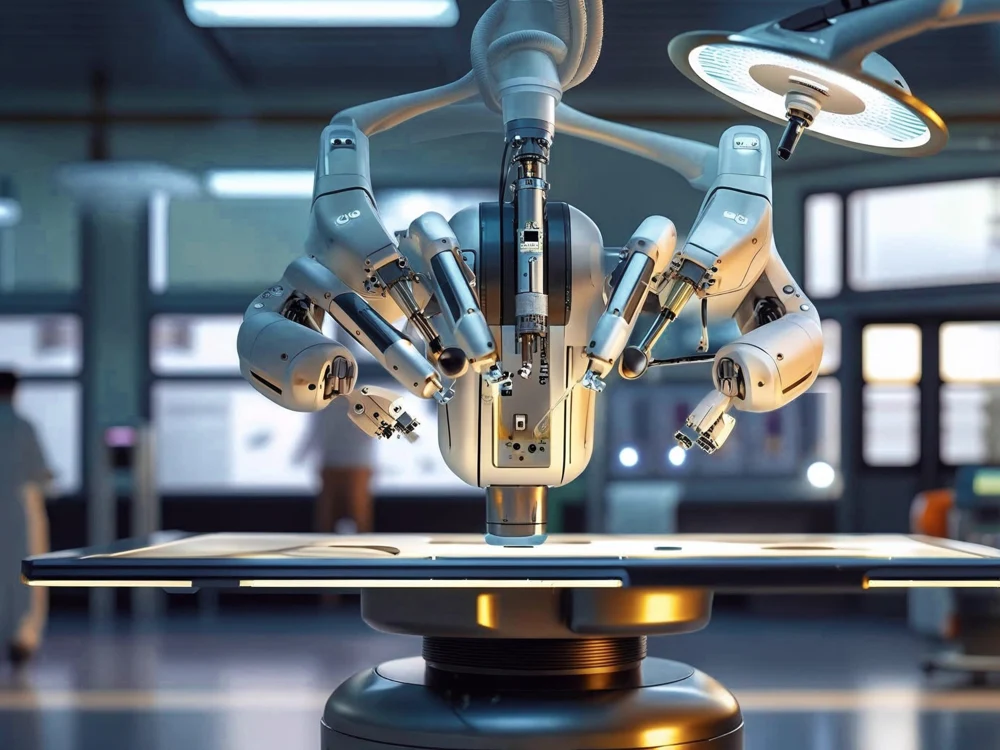
مختبر الأجهزة
Surgical Robot
The console is an operator workstation, not an autonomous decision maker. Find the viewing interface, hand controls and foot controls as separate inputs and outputs.
الأجزاء
قطعةً قطعة.
Surgeon console
The console is an operator workstation, not an autonomous decision maker. Find the viewing interface, hand controls and foot controls as separate inputs and outputs.
Viewing interface
A viewing interface turns the imaging chain into information the operator can use. The enclosed viewer and the open-console display are visibly different arrangements in this lab.
Master hand controls
The hand controls represent an input to the robot controller. The important relationship is between operator movement, the selected control mapping and instrument response.
Foot controls
Several functions may be assigned to foot controls in a real surgical system. Their shape and location are not enough to identify those functions across products.
System tower
The tower makes the distributed system visible. Its enclosure contains representative processing and power roles and supports a team display.
Team display and status interface
The bedside team needs a shared view of system status. The display in this lab reports the teaching state, input command and illustrative response.
Controller and processing electronics
The controller receives inputs and coordinates the represented drive response. It sits between a command and an actuator; it is not a guarantee that the physical system followed the command.
Power conversion and distribution
Power is a path through the system, not a single reassuring lamp. This schematic assembly represents the role of supplying usable electrical energy to processing and actuation.
System connections and communication
Follow the visible cables between console, tower and patient-side equipment. They make the distributed control problem tangible.
Patient-side base and supports
The base carries the mechanical assembly and transfers its loads to the floor. Compare a shared base with four independent carts.
ملاحظات الطُّرز