Medical City · Device Lab 12 of 69
TEE Probe
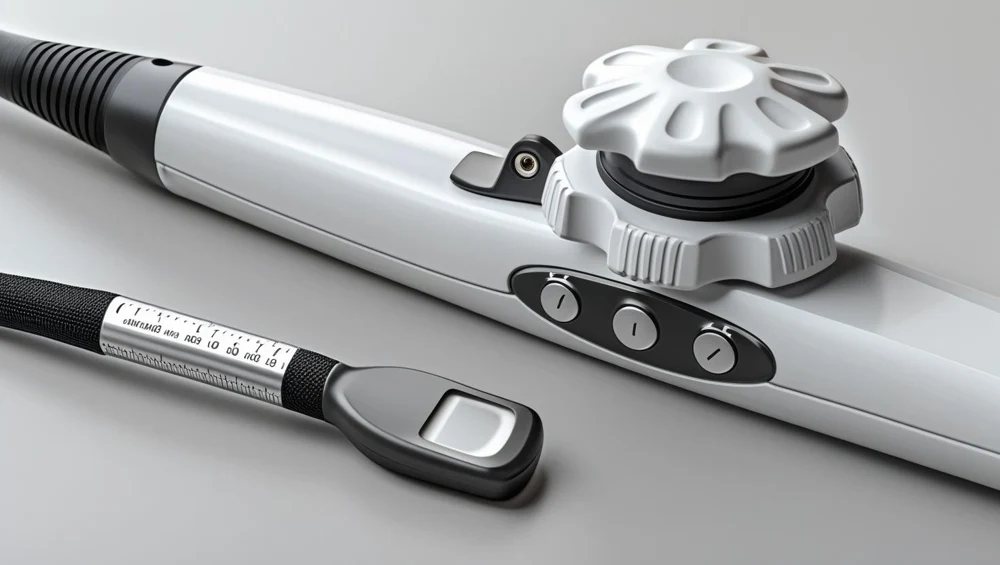
One row of sixty-four elements diced at half a wavelength, mounted on a carrier that a small motor in the tip rotates through a hundred and eighty degrees. The operator holds a button and the array turns; the angle is read from a potentiometer geared thirty to one on the motor side of the train and printed on the screen to the nearest degree. Behind the array is a backing block, and behind that the motor, its gearbox and a rotary seal, because the array turns inside a tip that has to be watertight enough to be immersed in disinfectant.
- 10 parts
- 2 configurations in the Device Lab
- Also called: Transesophageal Echo, Transoesophageal Echo
Configurations
The versions in the Device Lab.
Single-plane phased array with motor-driven multiplane rotation
One row of sixty-four elements diced at half a wavelength, mounted on a carrier that a small motor in the tip rotates through a hundred and eighty degrees. The operator holds a button and the array turns; the angle is read from a potentiometer geared thirty to one on the motor side of the train and printed on the screen to the nearest degree. Behind the array is a backing block, and behind that the motor, its gearbox and a rotary seal, because the array turns inside a tip that has to be watertight enough to be immersed in disinfectant.
Matrix array with electronically steered imaging plane
A forty-eight by forty-eight grid of two thousand three hundred and four elements at the same half-wavelength pitch, in a tip with no moving part in it at all. The imaging plane is produced by a delay pattern across the grid, so changing the plane angle is arithmetic rather than movement and two planes can be interleaved between frames. Two thousand three hundred coaxial cores will not pass down a ten millimetre shaft, so the first stage of beamforming is a chip immediately behind the array, reducing the channel count to something the shaft can carry -- and dissipating its power in the tip.
How it works
Explore it in the Device Lab.
One over four k a, and why the tip cannot grow its way out
Leave everything else alone and change only the apposed fraction of the acoustic face. Read the face equivalent radius, the spreading resistance, and the face temperature at each setting. Then compare the acoustic face with the tip shell.
A factor of four per degree, and the factor the machine does not hold
Set the tip power and read the face temperature and the thermistor temperature. Then leave both exactly where they are and change only the examination length. Read the accumulated equivalent time before and after.
A sensor that reads the hottest thing in the tip, and a fault that makes it safer
Read the face temperature and the thermistor temperature side by side at several powers and confirm which is the higher. Then inject the delaminated lens condition and read both again, and read the four resistances while you are there.
An aperture that turns with the plane, and one that does not
Set the plane angle to zero and read the in-plane aperture and the lateral resolution at a stated range. Then take the plane to forty-five degrees and read them again. Do it on both configurations.
A resolution of one hundredth of a degree, about the wrong thing
Read the plane encoder resolution referred to the array, then compare it with the step the display shows. Then introduce the lost-motion condition and watch which numbers change.
The parts
Part by part.
Mains inlet, isolation and protective earth
A filtered inlet on the back of the console, an isolation transformer behind it, and an equipotential stud beside it. Unremarkable on any medical electrical device, and on this one it carries a boundary that matters more than usual: the probe goes inside a person and its screen returns here.
Transmit pulser and the per-channel drive
A bank of high-voltage switching stages, one per transmit channel, that produce the short pulses the array radiates. It is the component that decides how much power enters the probe, and therefore the component that decides how hot the far end gets.
Preamplifier, time-gain compensation and digitiser
A low-noise preamplifier per channel, a gain that rises with time after the transmit pulse, and an analogue-to-digital converter behind it. It is the stage that turns microvolts into numbers, and its position in the system differs between the two configurations in a way that matters enormously.
Envelope detection, compression and scan conversion
The stage that turns beamformed radio-frequency data into a picture: it detects the envelope, compresses a very large dynamic range into the small one a display has, and converts the polar or steered geometry of the beams into the rectangular grid of a screen.
Display, the plane-angle readout and the tip temperature readout
The screen, and two small numbers on it that are not like the others. One is the imaging plane angle in degrees.
Console panel, acoustic output control and the freeze
The control surface: depth, gain, a plane-angle control, a mode selector, an acoustic output control and a freeze key. On this probe two of those controls do something no surface machine asks of them, and one of them is the only way an operator can reduce the heat in the far end.
Tip thermistor and the automatic freeze
A small thermistor bonded into the tip assembly close behind the array, two fine wires running the length of the shaft to the connector, and a comparator in the console that freezes the image when the temperature reaches a declared displayed value. It is the only self-measurement in this library that shuts a device down.
Piezocomposite stack, matching layer and backing block
The active layer and the two things bonded to its faces: a quarter-wavelength matching layer in front, taking the acoustic impedance of the ceramic down towards that of tissue, and a heavily loaded backing block behind, absorbing what goes the wrong way. It is the source of both the sound and the heat.
Acoustic lens and the conduction path into tissue
A thin layer of filled silicone rubber over the front of the stack, gently curved to focus in the elevation direction. It is the surface that touches tissue, and it is the last half millimetre of the only route the tip has for getting rid of its own heat.
Distal tip shell and the second contact patch
The moulded distal housing the array sits in: about twenty-six millimetres long, twelve and a half wide, eleven high, with rounded ends and a smooth finish. It is the part in the cavity, and it is the second and much larger of the two surfaces heat leaves through.
Next